CIVIL ROBOTICS & ACADEMIC LAB
Education & Research
Academic appointments, kinematics analysis, 5-DOF articulated teleoperation, and human-assisted task automation.
M.S. in Civil Engineering & Applied Robotics
2026 - 2032Graduate Studies & Research Team
Specializing in robotic task automation for civil infrastructure, human-robot interaction (HRI), inverse kinematics, and smart structural systems.
Human-Assisted Robotics Research Lab
2026 - PresentCivil Engineering Automation Division
Collaborative team research studying the automation of complex human tasks, focusing specifically on ergonomic human assistance, ease of interaction, and intuitive control frameworks.
Hardware & Embedded Systems Engineering
2026 - PresentSelf-Directed Systems Lab
Analytical 3D inverse kinematics solver, STM32 microcontroller firmware, 5-DOF articulated arm prototyping, and ROS2 companion systems.
5-DOF Articulated Kinematics & Automation Lab
Human-assisted civil infrastructure task automation & precision hardware integration
Telemetry Active
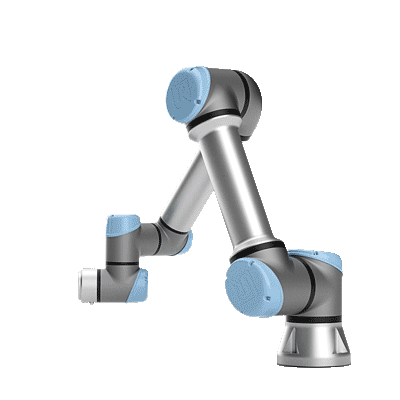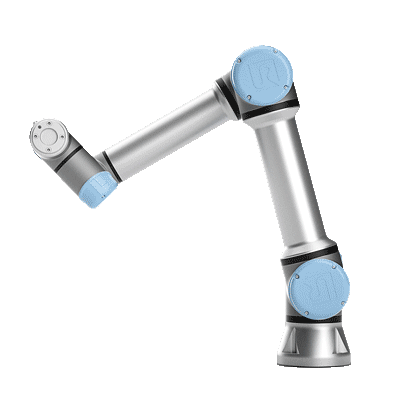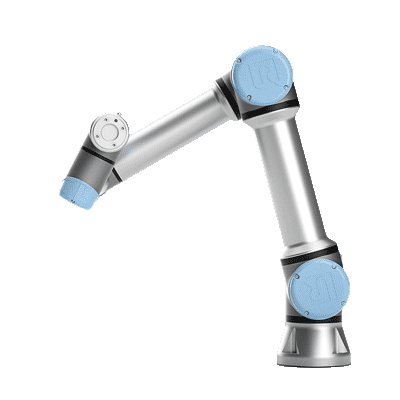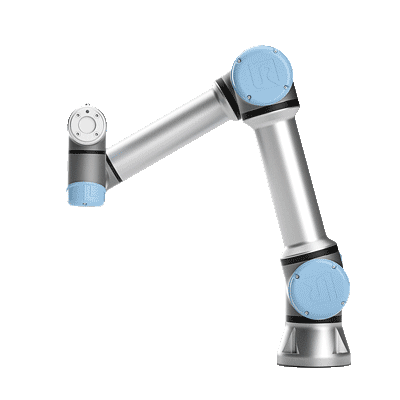
Geometric Kinematics Solver
5-DOF ALGORITHMClosed-form analytical inverse kinematics calculating exact joint angles in sub-millisecond cycles for smooth trajectory tracking.
Reach: 1.2 Meters
Payload: 15.0 kg
Human-Assisted Interaction
HRI INTERFACEErgonomic human-in-the-loop teleoperation frameworks designed for civil engineering operators with intuitive haptic feedback.
Latency: < 4.2ms
Control: Ergonomic HUD
Embedded Microcontroller Bus
STM32 / CAN-BUSReal-time motor actuation and optical encoder telemetry communicating via high-speed differential CAN-bus architecture.
Bus Speed: 1 Mbps
MCU: STM32F4 + ESP32